ORCAS
Orbital Risk & Conjunction Assessment System
Replacing Euclidean distance thresholds with rigorous collision probabilities in Low Earth Orbit using SGP4 propagation and B-plane covariance projection.
Open the full simulationThe Public Catalogue in 3D
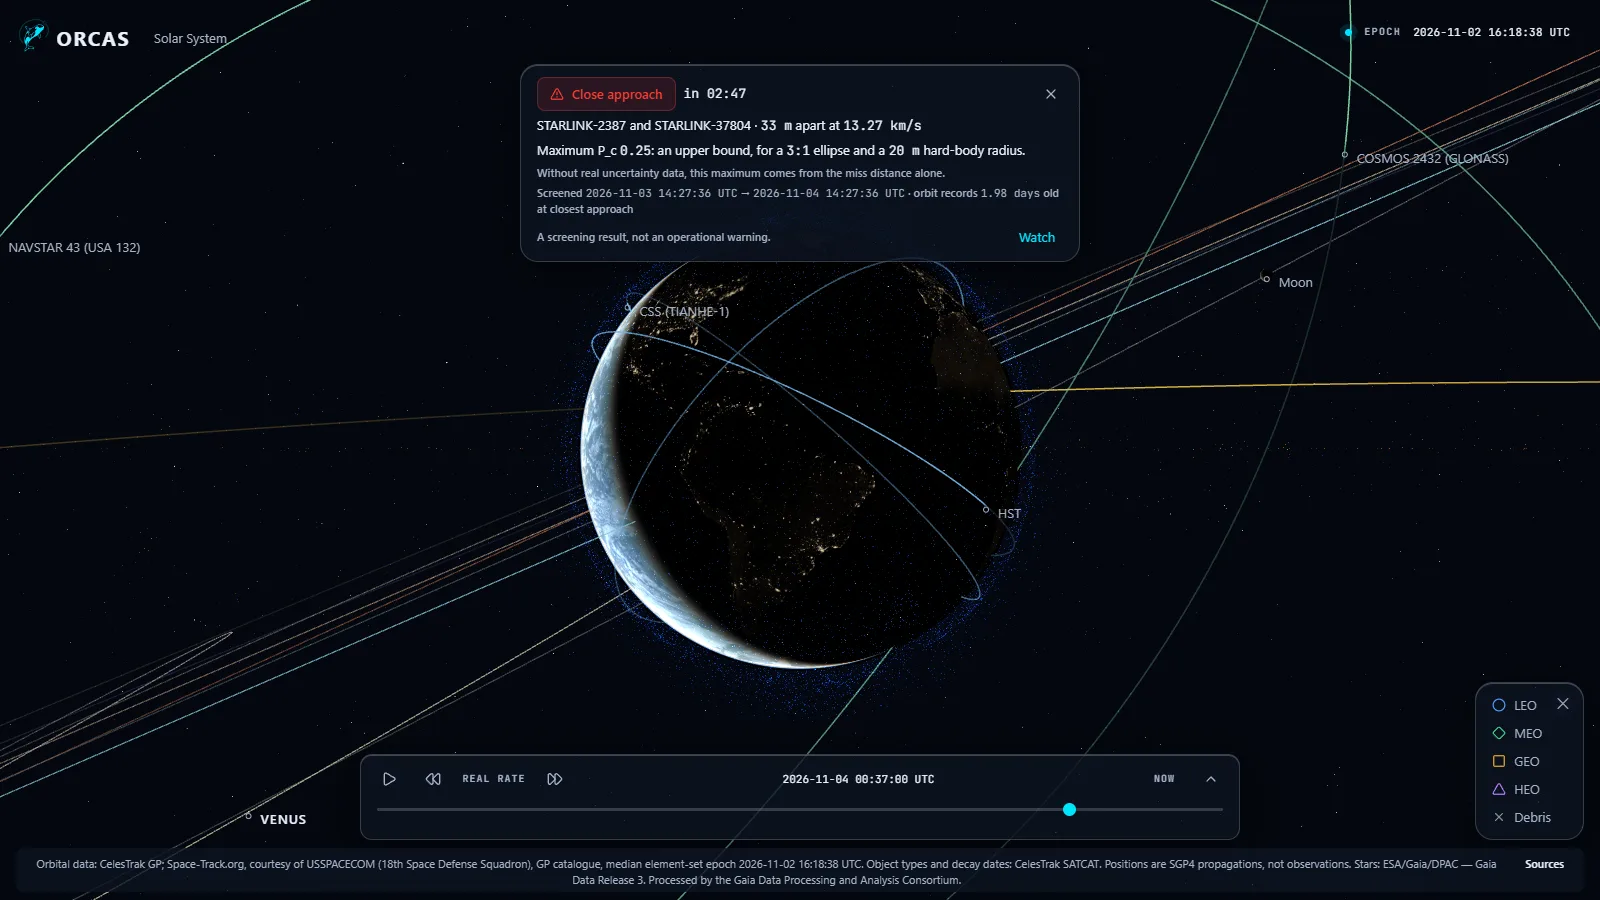
The real build: the public satellite catalogue propagated with SGP4 in your browser, with the day's screened close approaches. Best on a desktop browser.
Open full screen ↗Development Progress
- P0
Foundation
doneFresh monorepo, four-service Docker stack, CI — verified running.
- P1
Simulation backend
doneFastAPI, SGP4 propagation, covariance/conjunction pipeline, OMM ingestion, and a golden-file test reconstructing the real 2009 Iridium 33 / Cosmos 2251 collision from historical elements.
- P2
Data layer
nowIngestion from CelesTrak and Space-Track with SATCAT object types, retention, snapshot generation and historical replay are built. Ingestion and screening run by hand, not on a schedule; the 3D model pipeline is not started.
- P3
Design system
doneThe glass token system, motion language, and UI component set — the language this site borrows from.
- P4
The 3D frontend
nowBuilt: the whole public catalogue as GPU points, picking and selection, the camera system, search, reversible time, an object info panel, and the Earth, Sun and Moon on the simulation clock, checked against JPL DE421. Still to come: 3D satellite models.
- P5
Integration and polish
nowCatalogue-wide conjunction screening with a labelled maximum P_c, a close-approach warning with a Watch replay, Earth's shadow, CSV ephemeris export, and the public static site, live since November 2026.
- P7
Solar System
nowThe planets with real mission maps and IAU rotation, Saturn's rings, the Lagrange points and the 19 major moons. Spacecraft are next.
Case Study & Validation
The problem
On 10 February 2009, at 16:56 UTC and an altitude of 788.6 km over Siberia, the active communications satellite Iridium 33 collided with the derelict Cosmos 2251 at a relative velocity of 11.7 km/s. Standard deterministic algorithms had predicted a safe miss distance of over 500 metres.
They were not wrong about the distance. They were wrong to treat it as a distance.
Radar telemetry carries positional uncertainty. That uncertainty is a covariance matrix — an ellipsoid around the predicted position, oriented along the orbit. When two ellipsoids overlap substantially, the centres can be half a kilometre apart and the objects can still hit. Deterministic screening throws that information away at the first step, and the 2009 event is the demonstration of what that costs: the first accidental hypervelocity collision between two intact satellites, and a debris cloud we are still cataloguing.
The system
ORCAS replaces the distance threshold with a probability of collision.
Broad phase
An early prototype ingested Two-Line Element sets from CelesTrak and screened every
object against every other with a single scipy.spatial.cKDTree pass, cutting an O(n²)
sweep to roughly O(n log n). The rebuild takes OMM JSON as its canonical ingest format —
CelesTrak’s own TLE catalogue ran out of five-digit numbers in 2026 — keeping TLE only as
a legacy import adapter. The rebuilt catalogue screen propagates every object with SGP4,
finds close pairs with a k-d tree search whose radius provably catches every encounter
under 5 km, and refines each one to its time of closest approach. Given only a two-hour
window and no named pair, it rediscovers the 2009 Iridium 33 / Cosmos 2251 encounter from
the pre-event element sets.
Narrow phase
Surviving pairs go to the narrow phase, which is where the actual argument lives:
- Propagate both objects’ state vectors to the time of closest approach in ECI.
- Transform the covariance to ECEF through the Jacobian —
C_ECEF = J · C_ECI · Jᵀ. - Project onto the B-plane, the plane perpendicular to relative velocity at TCA —
C_B = P · C_c · Pᵀ. This collapses a three-dimensional encounter into the two-dimensional geometry that actually determines whether the objects intersect. - Integrate the 2D Gaussian over the combined hardbody cross-section to get P_c, by exact quadrature rather than an asymptotic approximation.
A separately trained Random Forest classifies tracked objects by type — payload, debris, rocket body — from their mean orbital elements. It never sees the Mahalanobis distance and isn’t part of the P_c pipeline above. It’s also retired from the product: a rigorous launch-grouped validation — the split that matters, since fragments of one breakup can otherwise land on both sides of a naive random split — found it reaches only 0.7604 ± 0.1609 accuracy, underperforming a naive majority-class baseline in 4 of 10 splits. No API route or screen uses its output today.
Rendering
The prototype rendered a GMST-synced rotating Earth with a ten-thousand-fragment
THREE.InstancedMesh Kessler-debris swarm and volumetric density heatmaps. The rebuild’s
React-Three-Fiber renderer draws the whole public catalogue as GPU points, with picking,
orbit paths, and the Earth, Sun and Moon on the simulation clock, checked against JPL
DE421; the synthetic debris swarm is a roadmap item below. Measured once, on
2026-09-14 in the scene’s debug view, at roughly 16,500 tracked objects and before debris
was added, a frame took about 7.5 ms of JavaScript and 1.7 ms of GPU time.
The validation
The method is only interesting if it changes an answer. Two things are worth keeping separate: what the published paper reported, and what the system can independently reproduce from real data.
As published (ICSSIT 2026). For the paper’s historical elements, under the simulated covariance the paper itself specifies — real public element sets carry none — the paper reports:
| Quantity | Value |
|---|---|
| Altitude at T₀ | 788.6 km |
| Velocity (Iridium 33 / Cosmos 2251) | 7.46 / 7.42 km s⁻¹ |
| Covariance determinant, primary | 2.4 × 10⁴ km² |
| Covariance determinant, secondary | 4.1 × 10⁴ km² |
| Mahalanobis distance D_M | 1.84 |
| Probability of collision P_c | 4.2 × 10⁻³ |
| Alert threshold | 1.0 × 10⁻⁴ |
That’s roughly 42× the alert threshold — under this assumed covariance, deterministic models of the day flagged the encounter as a miss; the paper’s probabilistic pipeline flags it critical. Those covariances can’t be recovered from public data, so the covariance-dependent figures above are quoted as published, not reproduced; for catalogue objects ORCAS reports a labelled maximum P_c instead.
Independently reproduced. Using only element sets published before the collision — no hindsight, no simulated covariance — the rebuilt engine puts closest approach at 16:55:59.796 UTC with a 698.0 m miss: inside the real-world SOCRATES warning system’s own 584 m call that week, and its 117 m – 1.812 km range. Separately, the P_c integration itself is checked directly against NASA’s own conjunction-assessment reference implementation, matching it on 12 of 12 published benchmark cases.
Status and scope
Done: SGP4 propagation engine, covariance/conjunction pipeline, catalogue-wide conjunction screening with a labelled maximum P_c, a close-approach warning, OMM ingestion with legacy TLE adapter, the planets and their major moons, and a golden-file test of the 2009 Iridium 33 / Cosmos 2251 historical reconstruction. The object classifier was built and is retired (above).
Roadmap: the Kessler debris swarm, scheduled ingestion and screening, 3D satellite models, spacecraft in the Solar System view, and the galactic scale.
Honest scope note: the simulation on this page is the real application, published as a static site: the public catalogue and the latest screening run, baked and refreshed by hand, so its data is as old as the element-set epoch it shows. The backend and its database run locally.
Reproducibility
The repository is public at
github.com/fenilmodi823/orcas. The full system —
backend, database and simulation — starts locally with one docker compose up.